
Used Robot Speed Records: Scaling Factors and Progress
2026-11-05
Used Robot Speed Records: Scaling Factors and Progress
Used Robot Speed Records should not treat one scaling field as a complete description of execution progress. The Universal Robots ROS 2 driver documentation describes a combined scaling value and a trajectory controller that uses scaled time. A handover needs to identify which quantity it actually supplies. This article reads a hypothetical used-robot appendix only. It changes no speed control, starts no controller, sends no trajectory, and observes no equipment.
Keep the two scaling fields and their combined use distinct
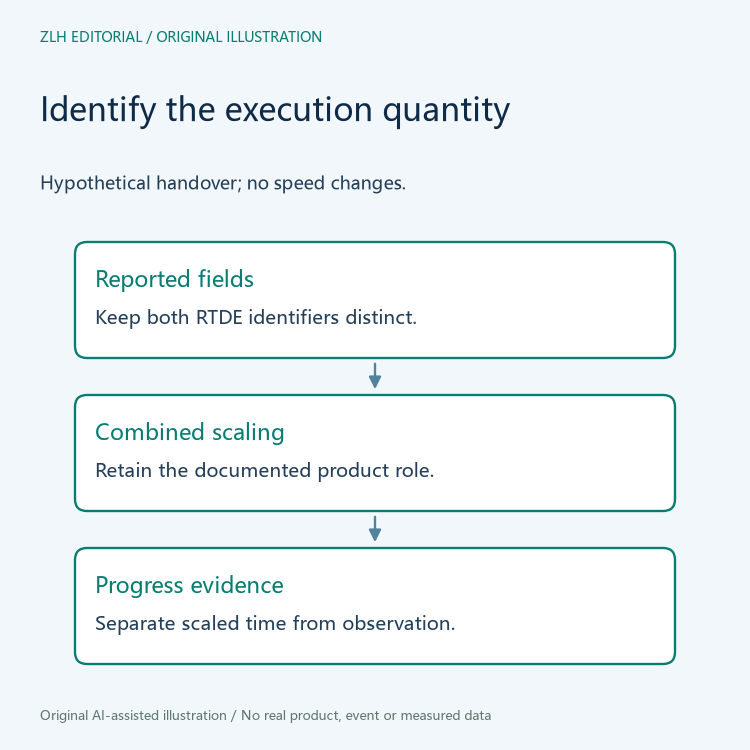
The official UR controller documentation explains that the driver calculates its reported execution-scaling quantity by multiplying speed_scaling and target_speed_fraction. A review should retain that product relationship instead of relabeling either individual field as the complete combined value. This article does not supply numerical factors or perform that calculation.
The official RTDE guide separately lists the two output fields. Its field table names a trajectory-limiter scaling and a target-speed fraction. This article preserves the field identifiers and the driver's stated combination without assigning an undocumented physical speed to either value. A fraction in this context is not a measured Cartesian velocity.
Scaled trajectory progress differs from unscaled elapsed time
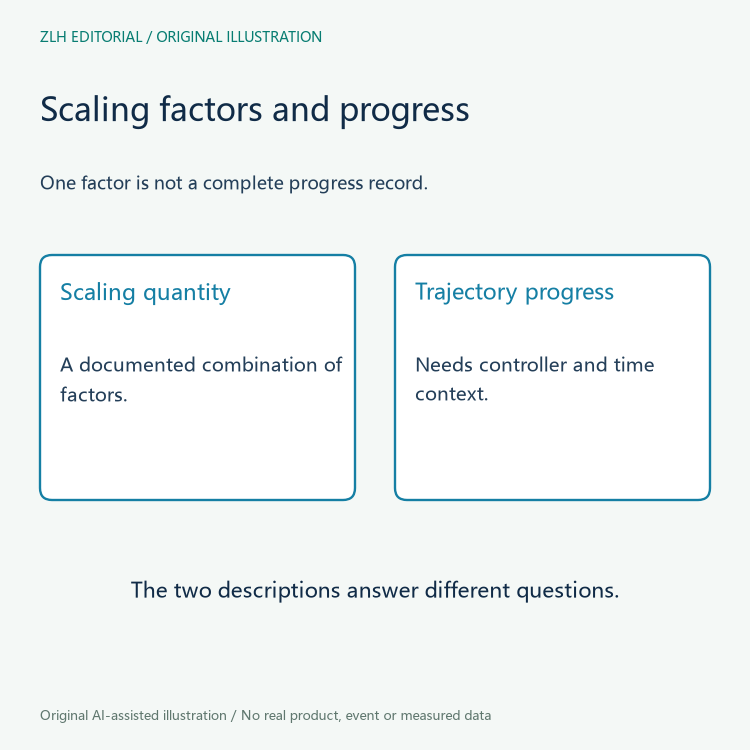
The controller explanation describes advancing trajectory interpolation by a fraction of the ordinary time step, determined by the current scaling. That is the relevant relationship for interpreting progress in its example. A nominal trajectory time does not automatically identify where actual execution has reached when scaling affects progression.
Suppose a fictional seller appendix says the program had been active for a stated interval and therefore must have passed a particular point. The reviewer can ask which controller and time interpretation support that statement. The elapsed interval alone is insufficient for the inference described here. This article contains no real duration, point record, or assessment of a unit's motion.
Identify the controller described by the appendix
The UR page distinguishes its scaled controller from the general joint-trajectory controller and explains why robot-reported scaling matters. A handover should name the controller it discusses rather than rely on a generic trajectory heading. Documentation of a specialized controller is not evidence that a particular installation used it.
A useful hypothetical attachment can identify the driver reference version, controller type, scaling fields supplied, and the source of any claimed progress observation. If the source gives only one factor, retain that limitation. Do not reconstruct a complete scaling history from one sample or infer that an unsupplied second factor remained constant.
Do not convert a scaling label into a condition finding
The documentation discusses circumstances that can slow or pause progression. Those explanations should remain manufacturer context, rather than a diagnosis of an offered unit. A low or zero value in an actual record would need its own surrounding evidence before a cause could be stated. This hypothetical article has neither such a record nor a basis for declaring a stop condition.
Likewise, a positive scaling value would not prove that a tool completed useful work or that the system met a path requirement. A scaling quantity and a task-completion observation answer different questions. The documentation's illustrative plots explain its controller behavior; they are not performance tests of the used robot in a seller's listing.
A clear review note can separate nominal trajectory information, the kind of scaling quantity, scaled-progress explanation, and actual execution evidence. It can confirm that these objects are named clearly without promising that a particular path was followed. If the contributor supplies a later observation, retain its capture context rather than using it to fill gaps in an earlier appendix.
Corrections should identify what changed. Replacing a vague speed heading with the exact RTDE field name may be a documentation revision only. A new computed product, a new controller record, or an actual equipment change each needs its own source. Do not describe all of them with one generic “speed corrected” phrase.
Time association matters even when both factor names are present. Values copied from unrelated moments do not automatically describe one current combined quantity. A contributor should identify whether an attachment contains paired observations, separate examples, or explanatory placeholders. Retain that distinction before describing a product as a recorded execution fraction. This article does not merge samples or interpolate a missing history. Its diagrams deliberately show roles rather than data points so that no invented temporal correspondence is implied.
The two original illustrations show quantity relationships without numeric scaling values, path curves, or robot movement. Additional context is available in the used robot documentation section and related resources section. Separating individual factors, their documented combination, and trajectory progress makes a handover more precise while keeping machine-condition claims attached to actual machine evidence.


